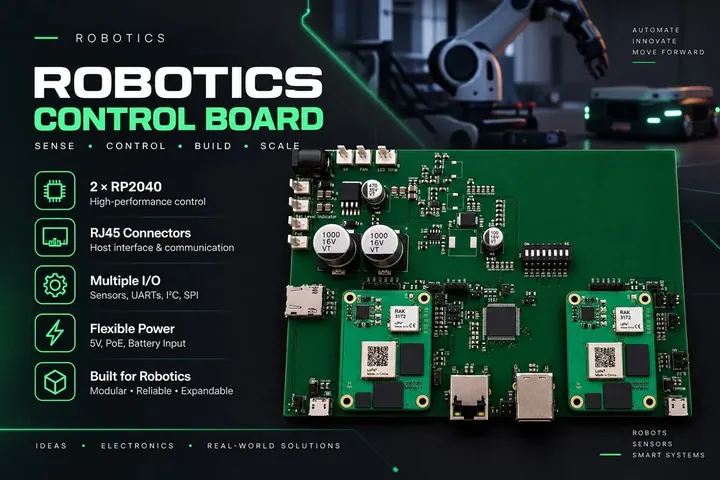
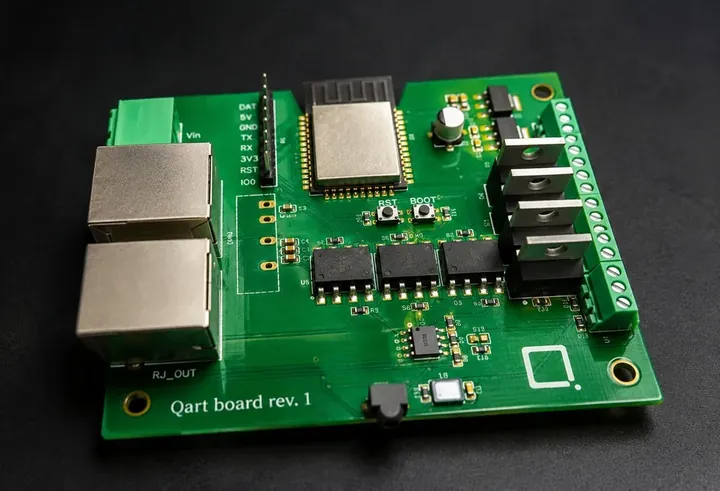
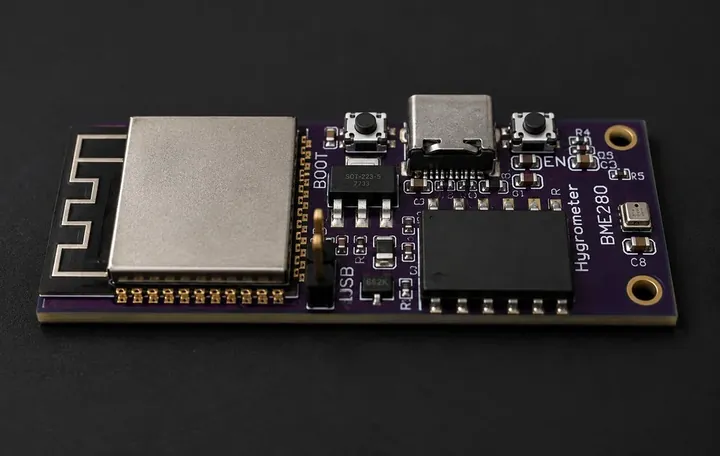
Robotics Wireless Control Interface
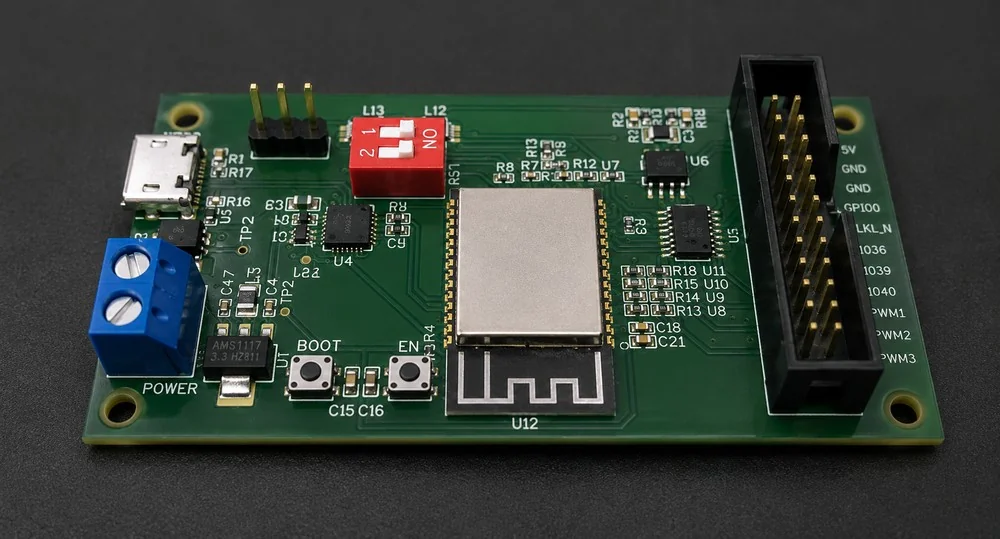
ESP32-based control board exposing a large GPIO header, power input and configurable I/O for robotics integration.
Project overview
ESP32-based control board exposing a large GPIO header, power input and configurable I/O for robotics integration.
Engineering approach
Robotics controllers need to juggle real-time control loops, sensor input, and actuator output without the layout introducing timing jitter or noise into the control path. On this board, that translates into a component set built around 4L and ESP32, with layout and stack-up decisions driven by motor drive integrity, sensor fusion timing, and expansion headers that keep the platform flexible.
Technical specification
Engineering focus
This portfolio project demonstrates CircuitNexa's electronics engineering and PCB design work in the robotics space. The design shown here is part of a broader portfolio spanning schematic capture, PCB layout, embedded firmware, prototyping, and support through to manufacturing.
Building a hardware product?
CircuitNexa helps startups and engineering teams turn electronics concepts into manufacturable hardware.
Talk to CircuitNexa